[{"@type":"PropertyValue","name":"Total duration","value":"≈ 50,000 hours"},{"@type":"PropertyValue","name":"Capture viewpoints","value":"6 hardware-synchronized streams (head main / secondary, left wrist main / secondary, right wrist main / secondary)"},{"@type":"PropertyValue","name":"Video specifications","value":"Head 1408×1280, wrist 640×480, 30 fps, H.264"},{"@type":"PropertyValue","name":"State recording","value":"51 columns at 30 Hz, strictly aligned with video frames; 21 measured state columns, 6 time index columns, 24 reserved placeholder columns"},{"@type":"PropertyValue","name":"Annotation granularity","value":"High-level task description + subtask timeline"},{"@type":"PropertyValue","name":"Storage format","value":"LeRobot v2.1 (Parquet + MP4)"}]
{"id":2300,"datatype":"1","titleimg":"https://www.nexdata.ai/shujutang/static/image/index/datatang_tuxiang_default.webp","type1":"282","type1str":null,"type2":"283","type2str":null,"dataname":"50000 Hours UMI Embodied Manipulation Dataset","datazy":[{"title":"Total duration","content":"≈ 50,000 hours"},{"title":"Capture viewpoints","content":"6 hardware-synchronized streams (head main / secondary, left wrist main / secondary, right wrist main / secondary)"},{"title":"Video specifications","content":"Head 1408×1280, wrist 640×480, 30 fps, H.264"},{"title":"State recording","content":"51 columns at 30 Hz, strictly aligned with video frames; 21 measured state columns, 6 time index columns, 24 reserved placeholder columns"},{"title":"Annotation granularity","content":"High-level task description + subtask timeline"},{"title":"Storage format","content":"LeRobot v2.1 (Parquet + MP4)"}],"datatag":"UMI,Pyhsical AI,Embodied AI","technologydoc":null,"downurl":null,"datainfo":null,"standard":null,"dataylurl":null,"flag":null,"publishtime":null,"createby":null,"createtime":null,"ext1":null,"samplestoreloc":null,"hosturl":null,"datasize":null,"industryPlan":null,"keyInformation":null,"samplePresentation":[{"name":"1792979275205.png","url":"https://storage-product.datatang.com/damp/product/sample_presentation/20261026094803/1792979275205.png?Expires=4102415999&OSSAccessKeyId=LTAI5tEBeSWUJiqjXvBMsxEu&Signature=kZmR6ZXmoG8xaI2uDKcgilvuIxs%3D","intro":"video","size":1503607,"progress":100,"type":"jpg"}],"officialSummary":"A large-scale, real-world teleoperation dataset for embodied AI manipulation, captured in genuine homes with the portable uDAS 1.0 system. It spans ~50,000 hours of valid footage: ~934,000 episodes (avg. 3.2 min each) covering everyday household activities, and ~19.2 million subtask segments. Each episode synchronously records six first-person video streams — head cameras at 1408 × 1280 and wrist cameras at 640 × 480, all 30 fps H.264 — plus 30 Hz proprioceptive data: bimanual end-effector 6-DoF poses, gripper opening and torso pose. Annotation is two-level (task description + subtask timeline) and three-dimensional (scene / object / action, 8 / 13 / 30 multi-tag categories), so any single dimension can serve as an independent evaluation split. Data is delivered in LeRobot v2.1 format by episode and chunk, ready to load out of the box, directly supporting pre-training, fine-tuning and cross-scenario generalization of vision-language-action (VLA) models.","dataexampl":null,"datakeyword":["Pyhsical AI","Embodied AI"],"isDelete":null,"ids":null,"idsList":null,"datasetCode":null,"productStatus":null,"tagTypeEn":"Type","tagTypeZh":null,"website":null,"samplePresentationList":null,"datazyList":null,"keyInformationList":null,"dataexamplList":null,"bgimg":null,"datazyScriptList":null,"datakeywordListString":null,"sourceShowPage":"embodiedAi","dataShowType":"[{\"code\":\"0\",\"language\":\"ZH\"},{\"code\":\"1\",\"language\":\"ZH\"},{\"code\":\"2\",\"language\":\"EN,JP,KO\"},{\"code\":\"3\",\"language\":\"EN\"}]","productNameEn":"50000 Hours UMI Embodied Manipulation Dataset","BGimg":"","voiceBg":["/shujutang/static/image/comm/audio_bg.webp","/shujutang/static/image/comm/audio_bg2.webp","/shujutang/static/image/comm/audio_bg3.webp","/shujutang/static/image/comm/audio_bg4.webp","/shujutang/static/image/comm/audio_bg5.webp"]}
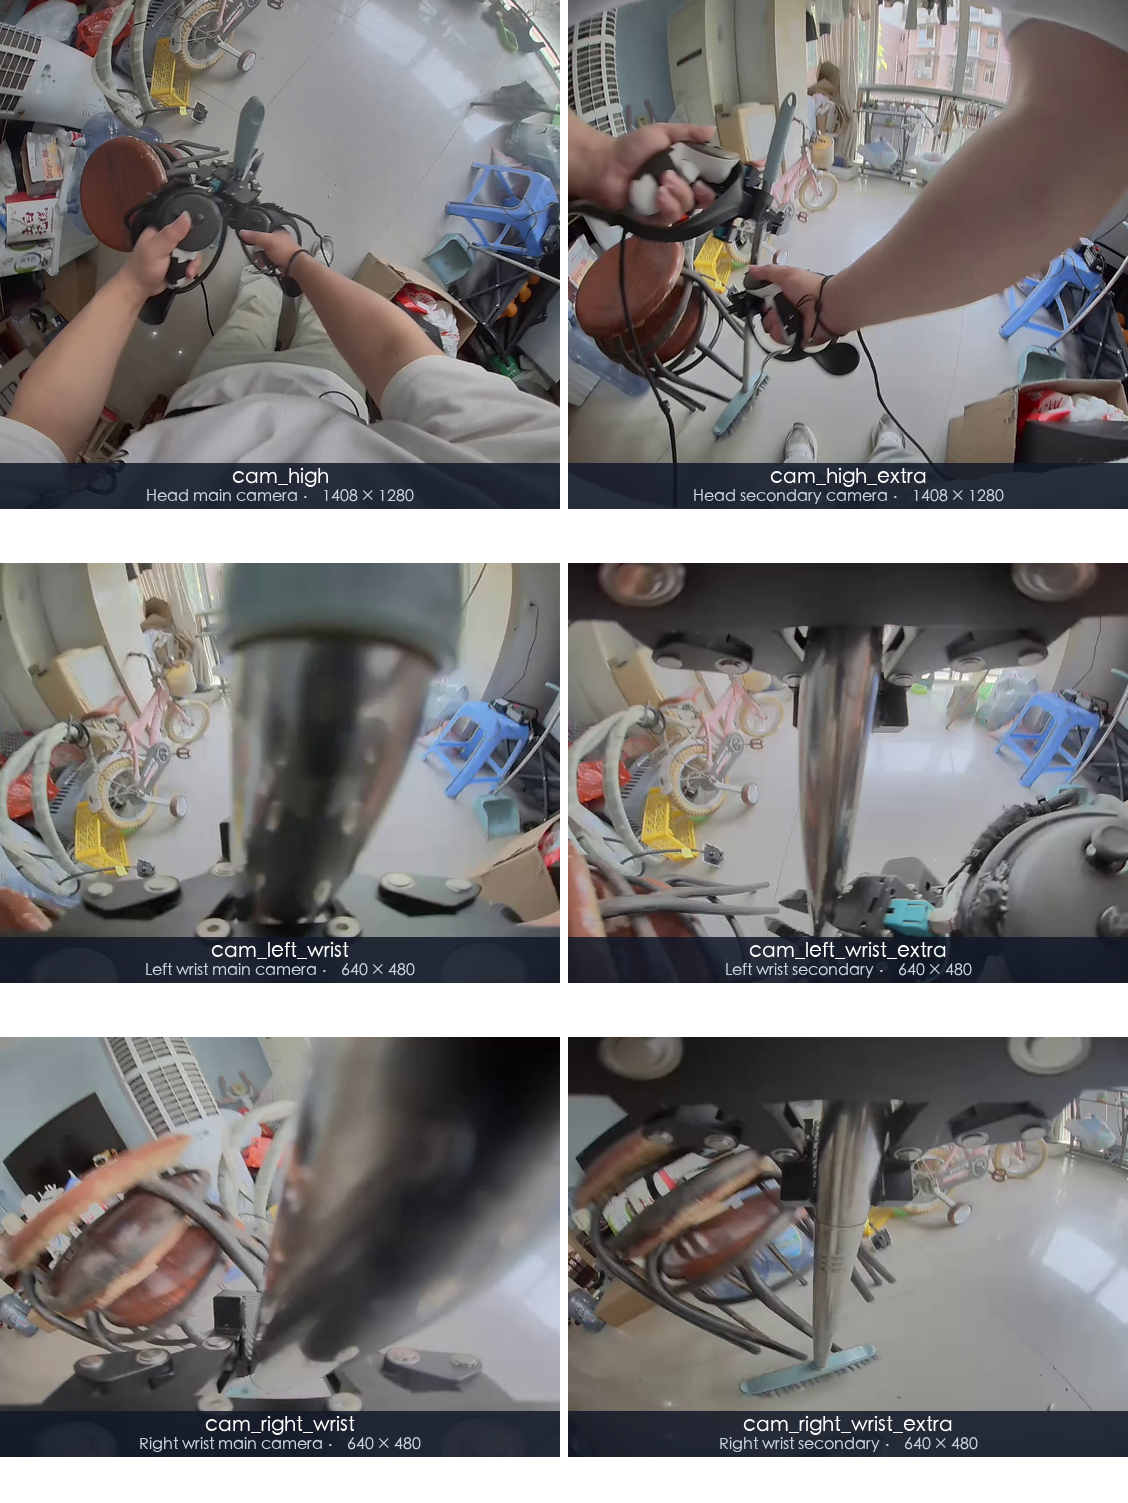
A large-scale, real-world teleoperation dataset for embodied AI manipulation, captured in genuine homes with the portable uDAS 1.0 system. It spans ~50,000 hours of valid footage: ~934,000 episodes (avg. 3.2 min each) covering everyday household activities, and ~19.2 million subtask segments. Each episode synchronously records six first-person video streams — head cameras at 1408 × 1280 and wrist cameras at 640 × 480, all 30 fps H.264 — plus 30 Hz proprioceptive data: bimanual end-effector 6-DoF poses, gripper opening and torso pose. Annotation is two-level (task description + subtask timeline) and three-dimensional (scene / object / action, 8 / 13 / 30 multi-tag categories), so any single dimension can serve as an independent evaluation split. Data is delivered in LeRobot v2.1 format by episode and chunk, ready to load out of the box, directly supporting pre-training, fine-tuning and cross-scenario generalization of vision-language-action (VLA) models.
This is a paid dataset licensed for commercial use. Ready-made datasets are available for immediate integration into AI projects.
Specifications
Total duration
≈ 50,000 hours
Capture viewpoints
6 hardware-synchronized streams (head main / secondary, left wrist main / secondary, right wrist main / secondary)
Video specifications
Head 1408×1280, wrist 640×480, 30 fps, H.264
State recording
51 columns at 30 Hz, strictly aligned with video frames; 21 measured state columns, 6 time index columns, 24 reserved placeholder columns
What types of Embodied AI applications can Nexdata’s datasets support?
Nexdata’s Embodied AI datasets are designed to support a wide range of robotics and embodied intelligence applications, including robot perception, manipulation, navigation, human-robot interaction, and Vision-Language-Action (VLA) model development. Depending on the dataset, data may include multimodal video, sensor data, robot trajectories, actions, poses, and other annotations for training and evaluation.
Can Nexdata customize Embodied AI datasets based on our specific requirements?
Yes. If our off-the-shelf datasets do not fully meet your requirements, Nexdata provides flexible custom data collection, annotation, and curation services. We can customize data based on your target robot platform, tasks, environments, sensors, data volume, annotation requirements, and model specifications, helping you build datasets tailored to your specific Embodied AI or VLA project.
Can Nexdata support large-scale Embodied AI data collection projects?
Yes. Nexdata operates an 8,000-square-meter real-world data collection dojo that enables large-scale and diverse data collection for robotics and Embodied AI applications. The facility can support customized environments, task scenarios, robot operations, and multimodal data collection, allowing us to accommodate projects with complex requirements and large data volumes.


 Specifications
 Sample
 Recommended Dataset


